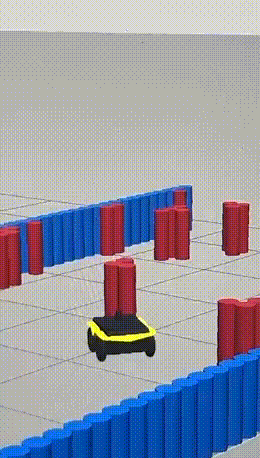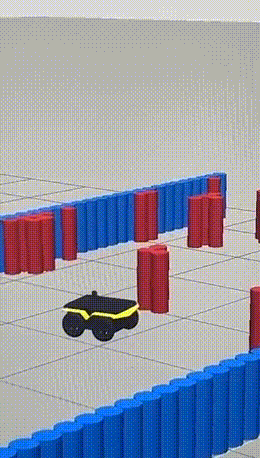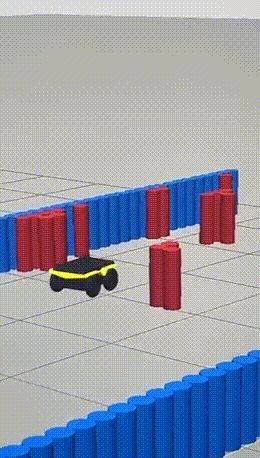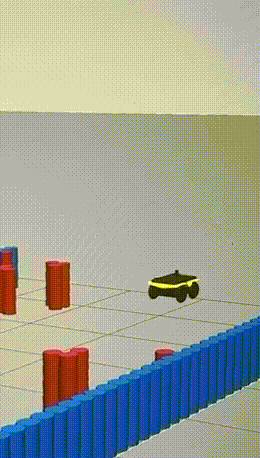
Used the Twin Delayed Deep Deterministic (TD3) algorithm to train an adaptive controller for jackal robot, achieving major improvements in navigation. Specifically, with the DWA algorithm, the controller increased the success rate from 72% to 89.47% and cut average navigation time from 76.64 seconds to 50.92 seconds across 300 simulations world in Gazebo