Hii! I’m a Master by Research student in AI and Machine Learning at Imperial College London, supervised by Prof. Stephen James at the Scalable Whole-body Intelligent Robot Learning (SWIRL) Lab. I completed my BEng in Electronic and Information Engineering at Imperial College London.
Prior to this, I did research with Berkeley Hybrid Robotics Lab, and interned at PsiBot on reinforcement learning post-training.
Find more in my Curriculum Vitae.
-
BiGym 2.0: Benchmarking Learned and Agent-Developed Policies for Humanoid Household Manipulation
Zexi Zhang*, Zecheng Zhu*, Zidong Chen, Zulkhuu Tuya, and Stephen James
Under review
A household-manipulation benchmark for a walking humanoid: BiGym adapted to the Unitree G1, with 20 tasks, 60 human virtual-reality demonstrations per task, and one shared whole-body controller. Under the same observations and actions, a cold-start coding agent averages 53% on nine tasks, close to a diffusion policy. Under review.
-
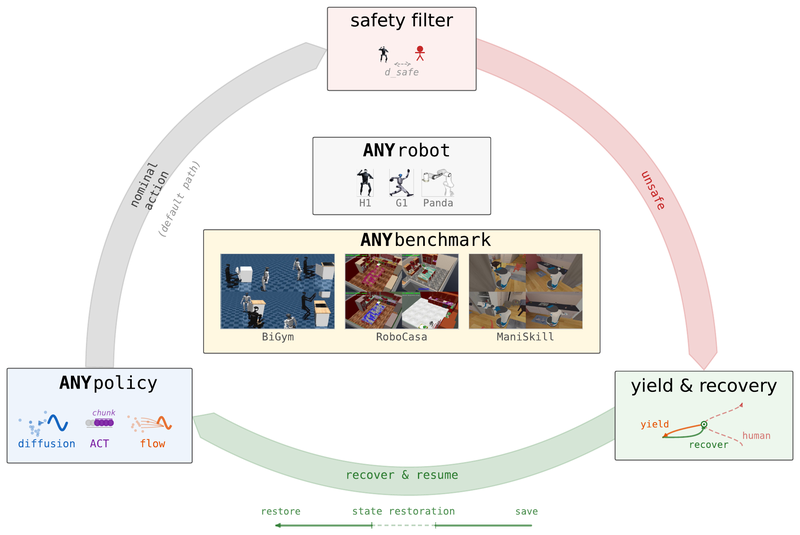
SafeYield: A Generalizable Recovery Framework for Safe Robot Manipulation
Zecheng Zhu and Stephen James
Under review
A recovery module on a frozen manipulation policy. It detects a person entering the workspace, yields, returns to the pre-interruption pose, and restores the policy so the task resumes instead of restarting. On 10 BiGym tasks, collisions fell from 78.8% to 1.6% and success rose from 57.6% to 75.6%. Under review.
-
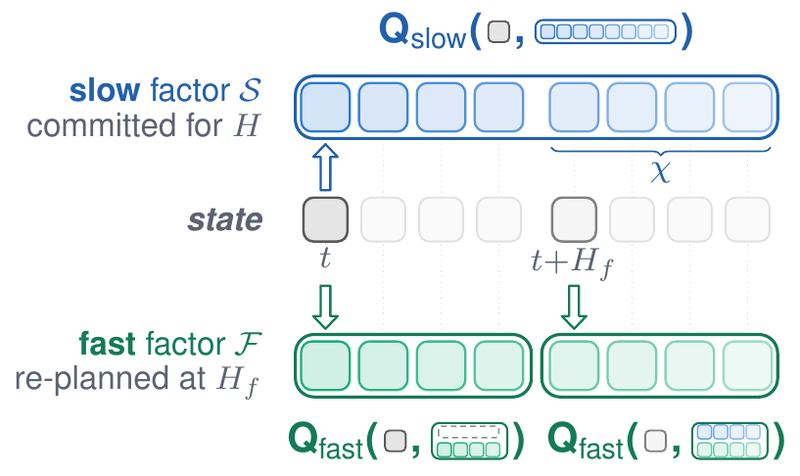
Factored Q-Chunking
Zecheng Zhu*, Hongze Yu*, and Stephen James
Under review
In reinforcement learning from demonstrations, the slow part of the robot commits for a full action chunk while the fast part re-plans halfway, and each critic scores only the actions it executes. With the same actor and budget as Q-chunking, online fine-tuning success went from 0.102 to 0.327 on an arm and hand, and from 0.302 to 0.480 on a mobile base with two arms. Under review.
* Equal contribution
Languages: Python, C++, C, SQL, SystemVerilog
Skills: Isaac Sim/Gym/Lab, PyTorch, ROS, Linux, Git, Embedded Platforms (ESP/STM)